5.1 Eigenvalues and Eigenvectors: Class Notes
Consider the equation .
Definition
If is an matrix, then a nonzero vector in is called an eigenvector of (or of the matrix operator ) if is a scalar multiple of ; that is, for some scalar . The scalar is called an eigenvalue of (or of ), and is said to be an eigenvector corresponding to .
In the equation above, is an eigenvalue of the matrix, and is its associated eigenvector.
Note that if , then . Then . Since (by the definition, an eigenvector is nonzero), we seek nontrivial solutions.
Theorem 5.1.1
If is an matrix, then is an eigenvalue of if and only if it satisfies the equation .
Definition
If is an matrix, then the characteristic equation of is .
Tip: The characteristic equation is sometimes written .
Definition
The characteristic polynomial of an matrix results from expanding the characteristic equation of and has the form .
Definition
The solution space of the system is called the eigenspace of corresponding to .
#6
In each part, find the characteristic equation, the eigenvalues, and bases for the eigenspaces of the matrix.
a. b. c. d.
Solution
a. Form and set its determinant equal to zero.
The characteristic equation is . Then
Substitute into to find :
Basis for the eigenspace: .
For :
Check: , and .
Answer:
b.
So , a repeated root (algebraic multiplicity 2).
For :
Basis: . Only one basis vector, so the geometric multiplicity is 1.
Answer:
c.
So (algebraic multiplicity 2). For , , so both and are free: , .
Basis: (geometric multiplicity 2).
Answer:
d.
Answer:
Theorem 5.1.3
If is an matrix, the following statements are equivalent.
- a) is an eigenvalue of .
- b) is a solution of the characteristic equation .
- c) The system of equations has nontrivial solutions.
- d) There is a nonzero vector such that .
#9
Find the characteristic equation, the eigenvalues, and bases for the eigenspaces of the matrix.
Solution
Set and expand along the second row, which has only one nonzero entry.
So (algebraic multiplicity 2) and .
For :
So and , which gives . The basis is .
For :
So and , which gives . The basis is .
Tip: This is the eigenvector from the equation at the start of the section: with and .
Answer:
#19
In each part, find the eigenvalues and the corresponding eigenspaces of the stated matrix operator on . Use geometric reasoning to find the answers. No computations are needed.
a. Reflection about the line .
b. Orthogonal projection onto the -axis.
c. Rotation about the origin through a positive angle of .
d. Contraction with factor
e. Shear in the -direction by a factor
Solution
In each part we look for nonzero vectors with : vectors that the operator sends to a scalar multiple of themselves.
a. If , then (on the line ) or (perpendicular to it).
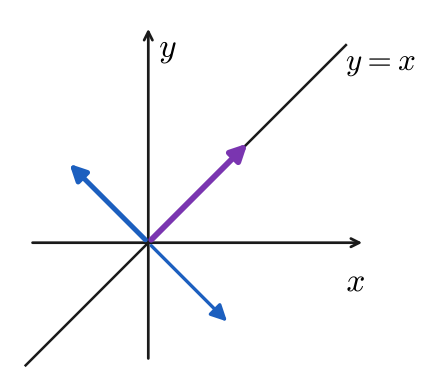
The line through the origin. A vector along the line (drawn in purple) is unchanged by the reflection. A vector perpendicular to the line, along (drawn in blue), is reflected to its opposite.
If , the reflection leaves it unchanged: , with eigenspace .
If , the reflection reverses it: , with eigenspace .
b. happens when is on the -axis, so it has the form , or on the -axis.
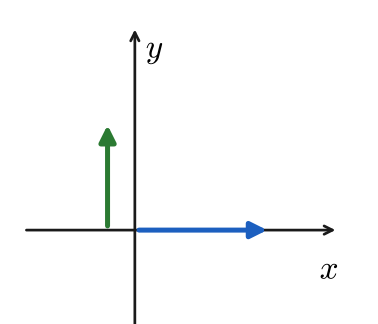
A vector on the -axis (blue) projects to itself. A vertical vector (green) projects to the zero vector.
On the -axis: , eigenspace .
On the -axis: , eigenspace .
c. A rotation through turns every nonzero vector to a perpendicular direction.
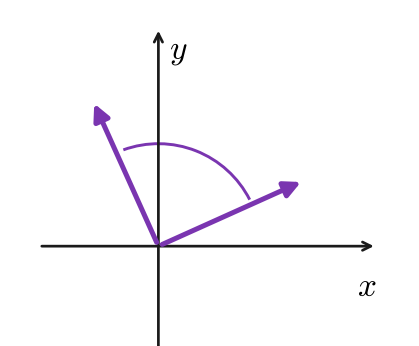
A vector (purple) and its image after a 90° rotation. The image is perpendicular to the original, so it is never a scalar multiple of it.
So doesn't happen for : the equation has no nonzero solution unless the angle of rotation is a multiple of .
Answer:
d. with . This applies to all vectors in .
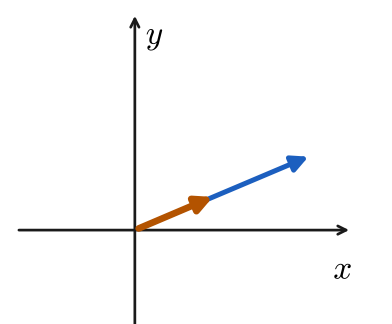
A vector (blue) and its image under the contraction (orange), which points in the same direction and is times as long.
So , with basis . The eigenspace is all of .
e. A shear in the -direction moves each vector horizontally by times its -value: goes to (see Section 8.6).
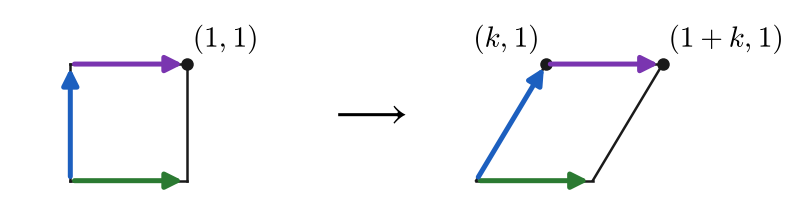
The unit square (left) and its image under the shear (right). The green vector along the -axis does not move. The corner moves to , and moves to (the blue vector tilts).
If , then , so with basis . Shearing any other vector (one with ) changes its direction, so the result is not a scalar multiple of the vector.
Answer:
Recall
The determinant of a diagonal or triangular matrix is the product of the entries on the main diagonal (Theorem 2.1.2). It follows that:
Theorem 5.1.2
If is an triangular matrix (upper triangular, lower triangular, or diagonal), then the eigenvalues of are the entries on the main diagonal of .
#14
Find the characteristic equation of the matrix by inspection.
Solution
The matrix is upper triangular, so is too, and its determinant is the product of its diagonal entries.
Answer:
#15
Find the eigenvalues and a basis for each eigenspace of the linear operator defined by the stated formula.
Solution
So .
Answer:
Theorem 5.1.4
A square matrix is invertible if and only if is not an eigenvalue of .
Proof
Recall that is an eigenvalue of if there is a nonzero vector such that . Then .
() Suppose is invertible. Then , so . But if were an eigenvalue, then . So is not an eigenvalue of .
() If is not an eigenvalue of , then there is no nonzero vector satisfying (that is, ). So the system has only the trivial solution, and therefore is invertible.
Theorem 5.1.5 Equivalent Statements (extends Theorem 4.9.8)
If is an matrix, then the following statements are equivalent.
- a) is invertible.
- b) has only the trivial solution.
- c) The reduced row echelon form of is .
- d) is expressible as a product of elementary matrices.
- e) is consistent for every matrix .
- f) has exactly one solution for every matrix .
- g) .
- h) The column vectors of are distinct and linearly independent.
- i) The row vectors of are distinct and linearly independent.
- j) The column vectors of span .
- k) The row vectors of span .
- l) The column vectors of form a basis for .
- m) The row vectors of form a basis for .
- n) has rank .
- o) has nullity 0.
- p) The orthogonal complement of the null space of is .
- q) The orthogonal complement of the row space of is .
- r) is not an eigenvalue of .